Single-camera 3D ball trajectory
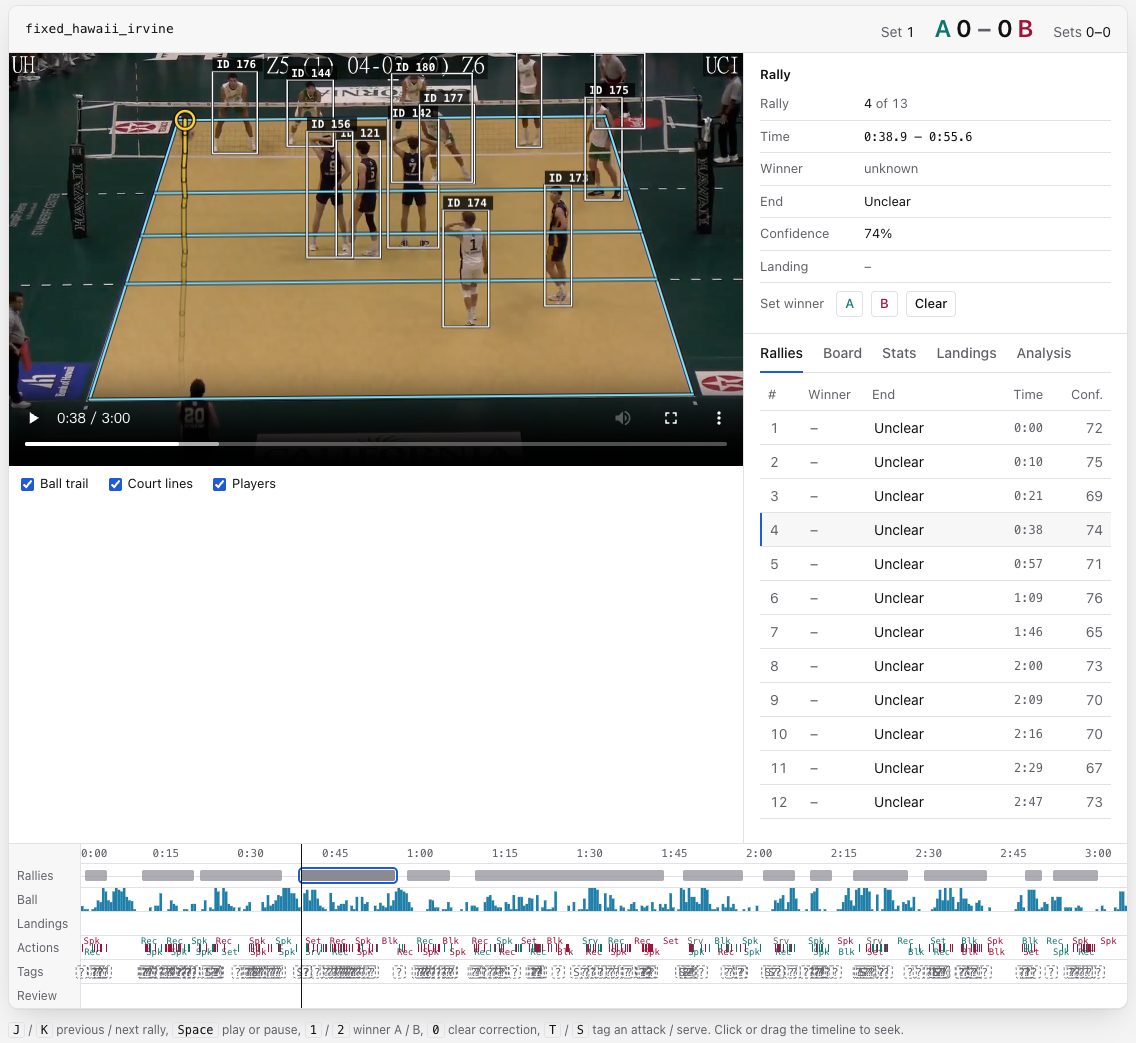
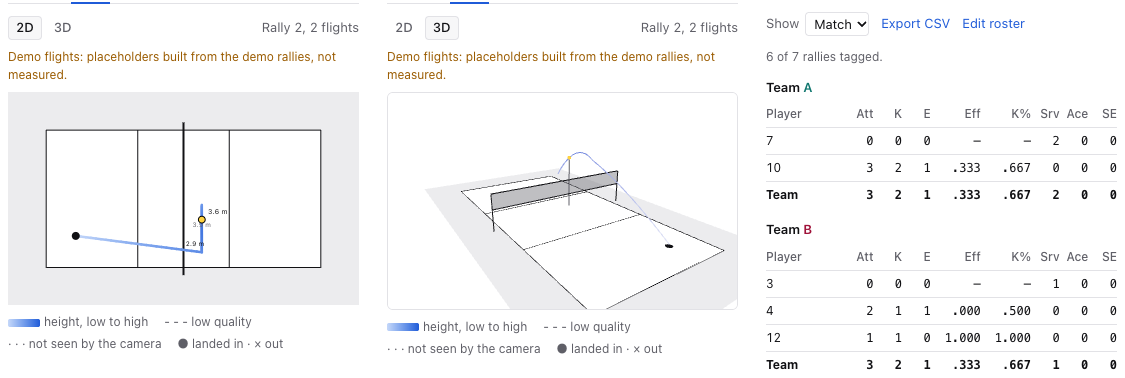
The court keypoints include the net band, which calibrates the camera fully. Between touches the ball follows a ballistic arc, so one camera’s rays plus gravity fix where the ball is in 3D — with an error per flight, and flights the camera cannot resolve marked as such.
Landing calls from one camera
Tennis and professional volleyball rely on several synchronised cameras. With one, the plan combines the 3D fit, learned event spotting and the sound of the bounce, and reports uncertainty near the lines.
Free labels from the score on screen
Match video carries its own answer key: the score bug changes after every point. Read with OCR and filtered by the rules of the game (one point at a time), it gives each rally’s end and winner, which trained the fixed-camera rally model and will measure automatic scoring.
Every number has a measurement behind it
Each component is scored with standard metrics (court error in metres; HOTA / IDF1 for players; mAP for actions; F1 for the ball). Results and the scripts that produce them live next to the code, and corrections are published when an earlier number turns out wrong.
Product requirements, behaviour specifications and results are in the repository.